Avalanche Photodiode Rangefinder: APD Receiver Guide
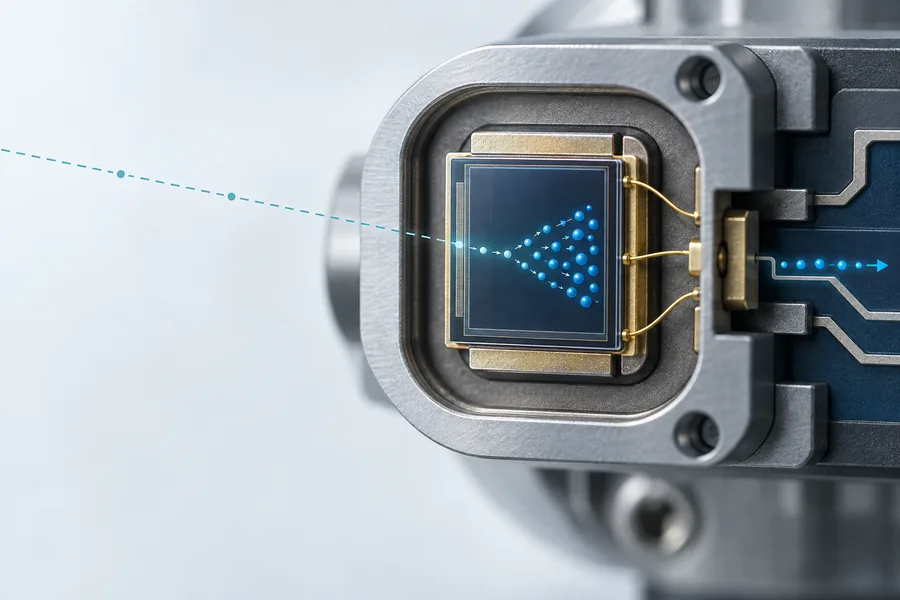
Learn how an avalanche photodiode rangefinder detects weak returns, why gain adds noise and bias complexity, and what OEM engineers should validate.
Direct ToF vs Indirect ToF: Which Method Fits?
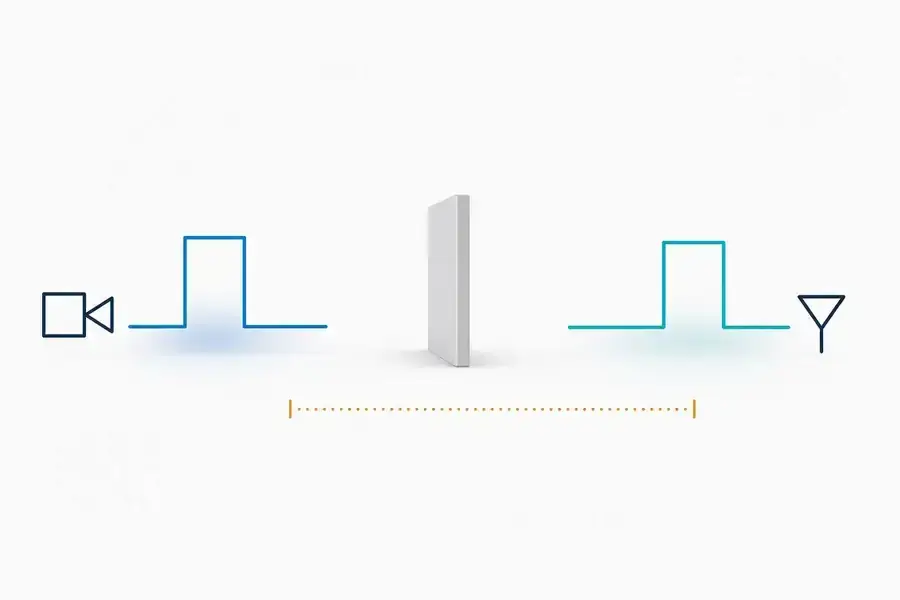
Compare direct ToF vs indirect ToF laser ranging methods, their trade-offs, and the integration inputs OEM teams should define first.
What Is Laser Ranging? Principles and OEM Considerations
What is laser ranging? Learn how time-of-flight and phase methods work and what OEM teams should evaluate before integration.
Laser Rangefinder Sensor vs Module: OEM Buyer Guide
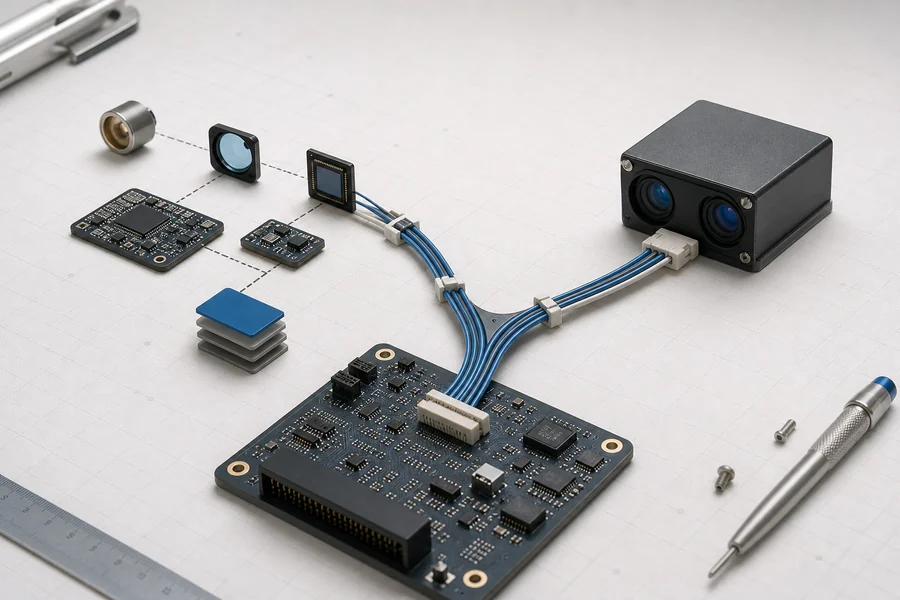
Compare a laser rangefinder sensor with an OEM module by integration boundary, optics, interfaces, validation, and production responsibility.
OEM Laser Rangefinder Supplier: 8 Evaluation Tests
Evaluate an OEM laser rangefinder supplier through sample evidence, manufacturing controls, scoped documents, change control, and production support.
How to Test Laser Rangefinder Modules Before Production
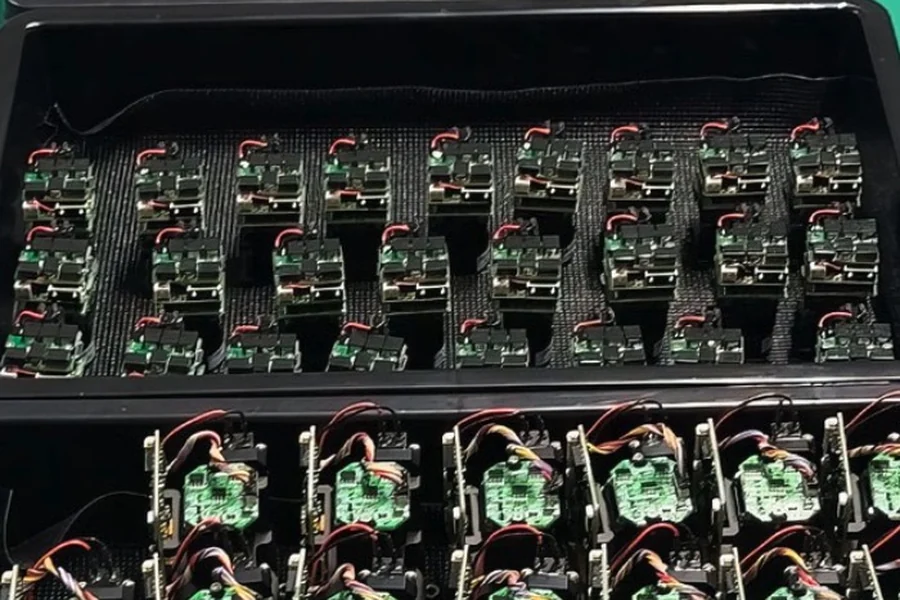
Learn how to test laser rangefinder modules with controlled references, representative targets, repeatability checks, and production-ready records.
Laser vs Ultrasonic Distance Sensor: Selection Guide
Laser vs ultrasonic distance sensor selection depends on target, footprint, environment, and timing. Compare failure modes and validation steps.
Laser Rangefinder Beam Divergence: Hit Probability Guide
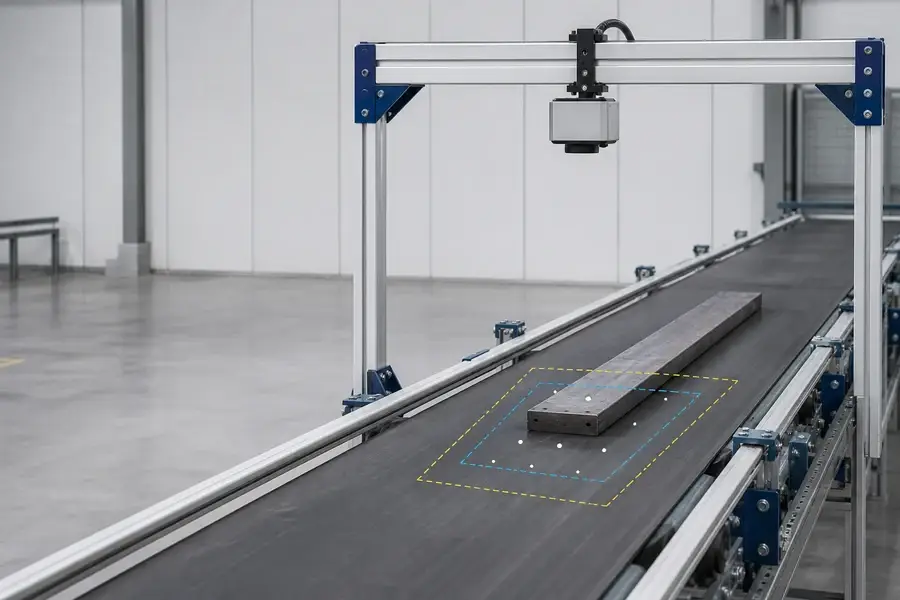
Laser rangefinder beam divergence changes spot size, pointing tolerance, and return strength. Learn how to compare mrad specs and validate target hits.
Laser Rangefinder in Fog: Rain, Haze and Range Loss
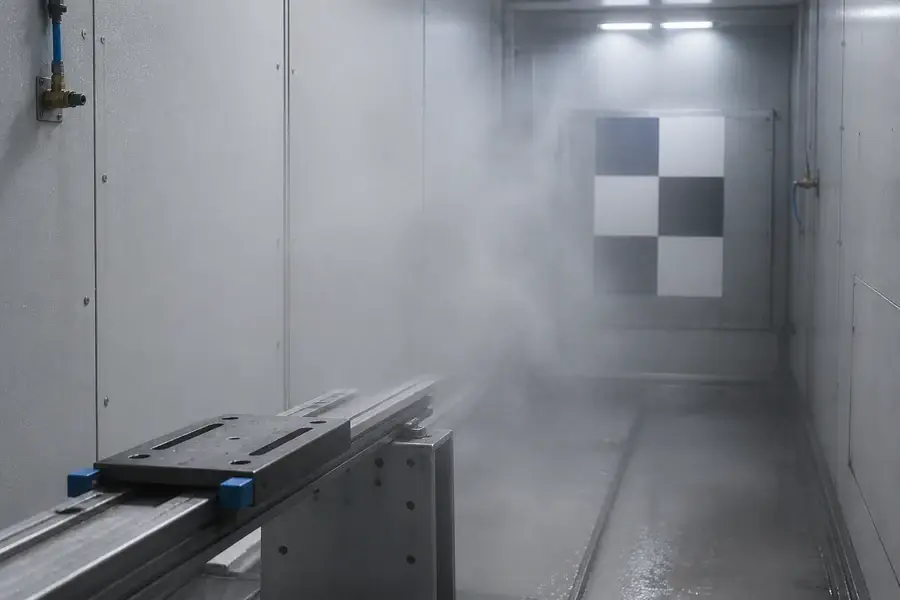
A laser rangefinder in fog loses range through attenuation and false echoes. Learn how rain and haze differ, what filters trade away, and how to test.
Rangefinder Target Reflectivity: What 10%, 30%, and 90% Mean
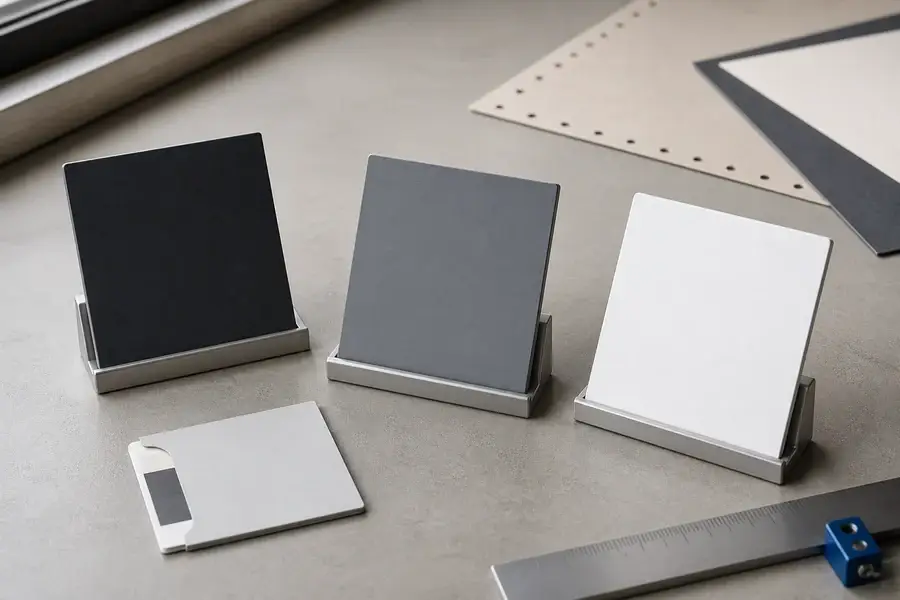
Rangefinder target reflectivity changes return strength, but 10%, 30%, and 90% are reference conditions—not a universal rule. Learn how to compare range claims.